Robotics engineer · London, UK
From an idea
to a working
prototype.
I’m Hishaam, a First Class Robotics Engineering graduate. I design, build and test physical systems, bringing mechanical hardware, electronics and code together.
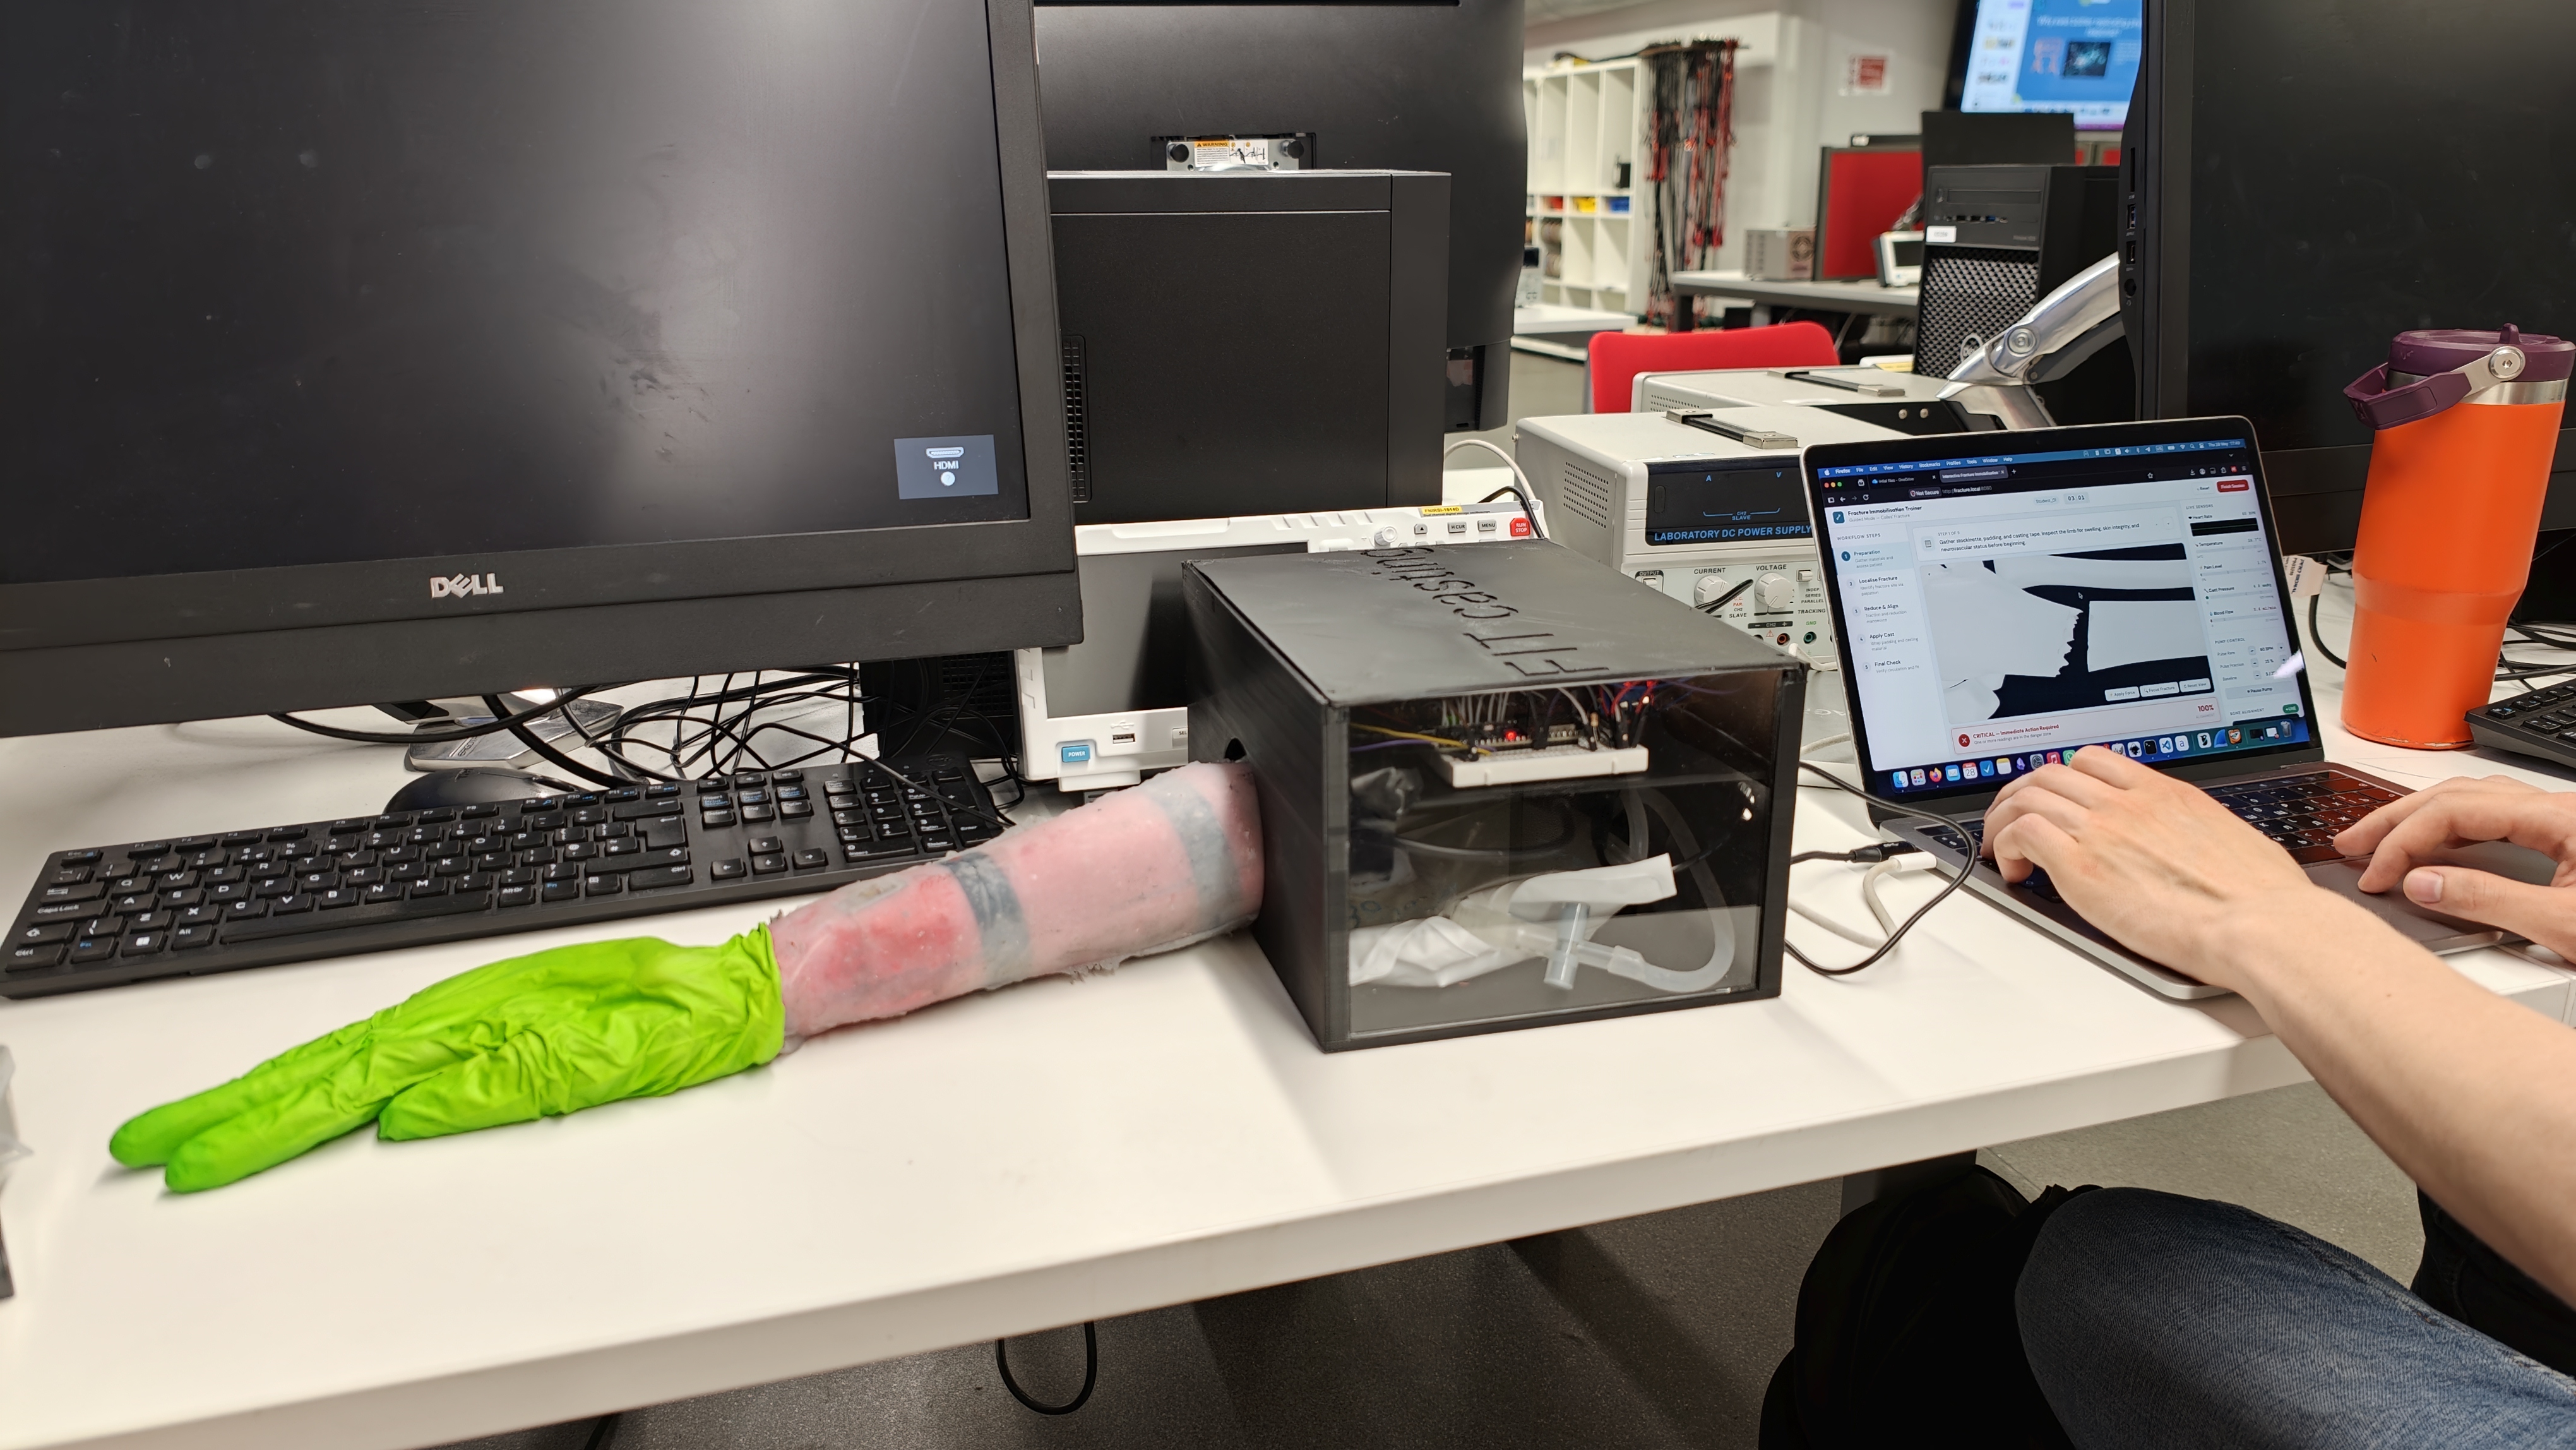 In the lab
01 / Selected work
Engineering, in practice.
Medical training · Design & manufacture
Fracture Immobilisation Trainer
An anatomical forearm with embedded sensing, layered silicone and a material study.
View case study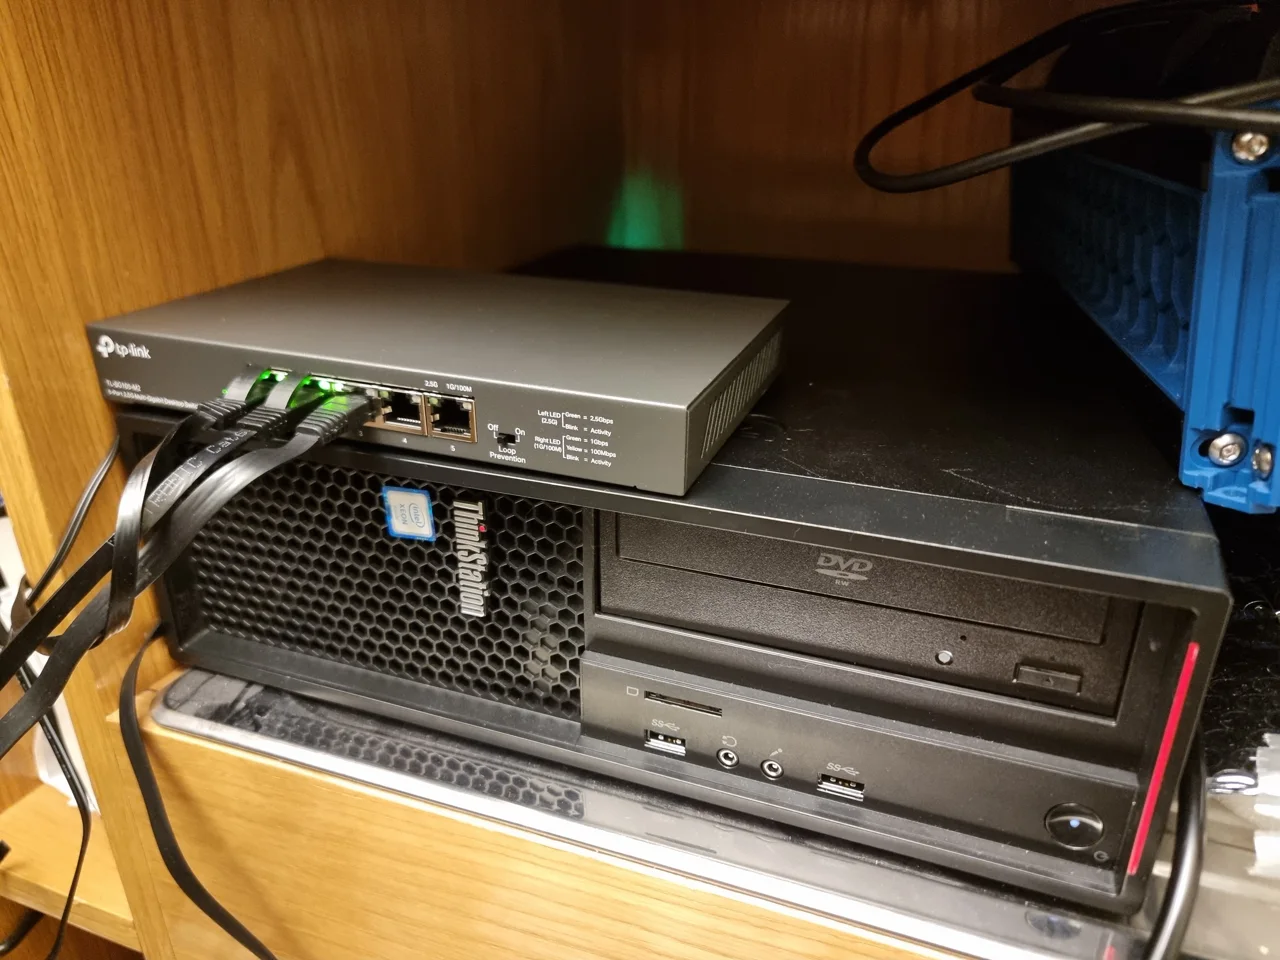
Infrastructure · Linux & networking
A home server for everyday use
A repurposed workstation running family services, GPU transcoding and four websites.
View case study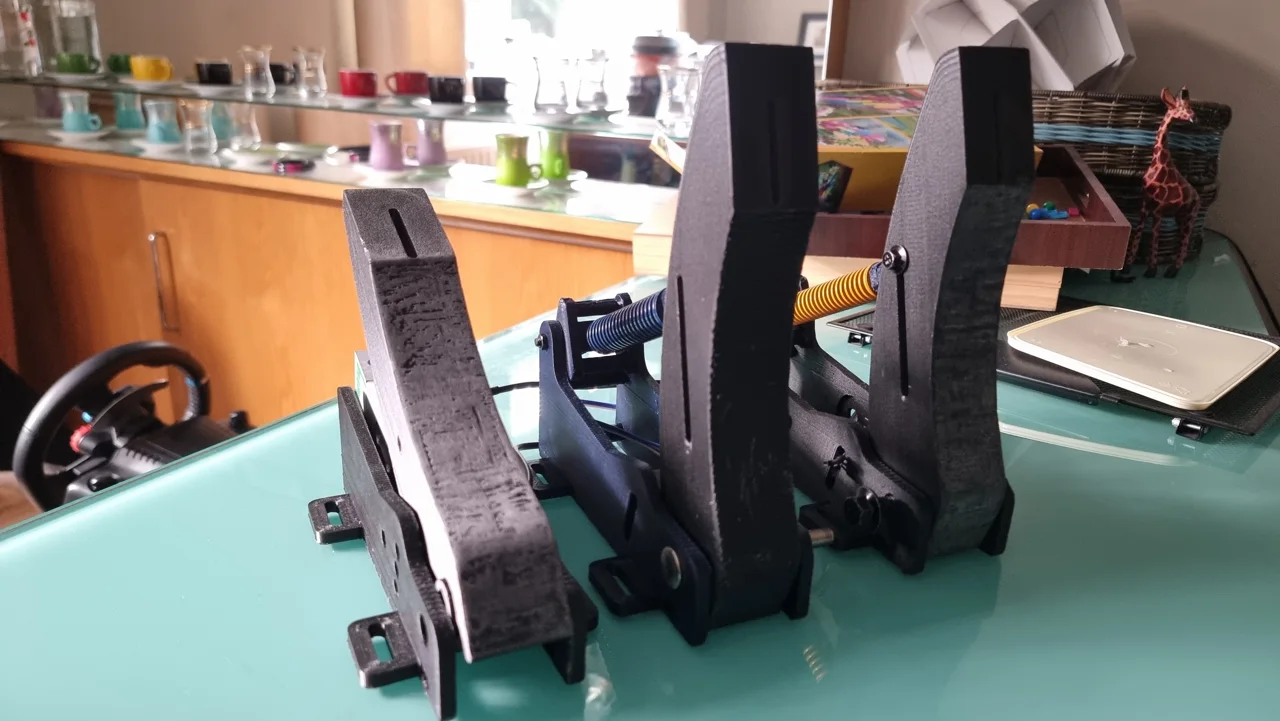
Personal build · Sensing & manufacture
Load-cell sim racing pedals
PETG-CF pedals with force-based braking and an experimental copper finish.
View case study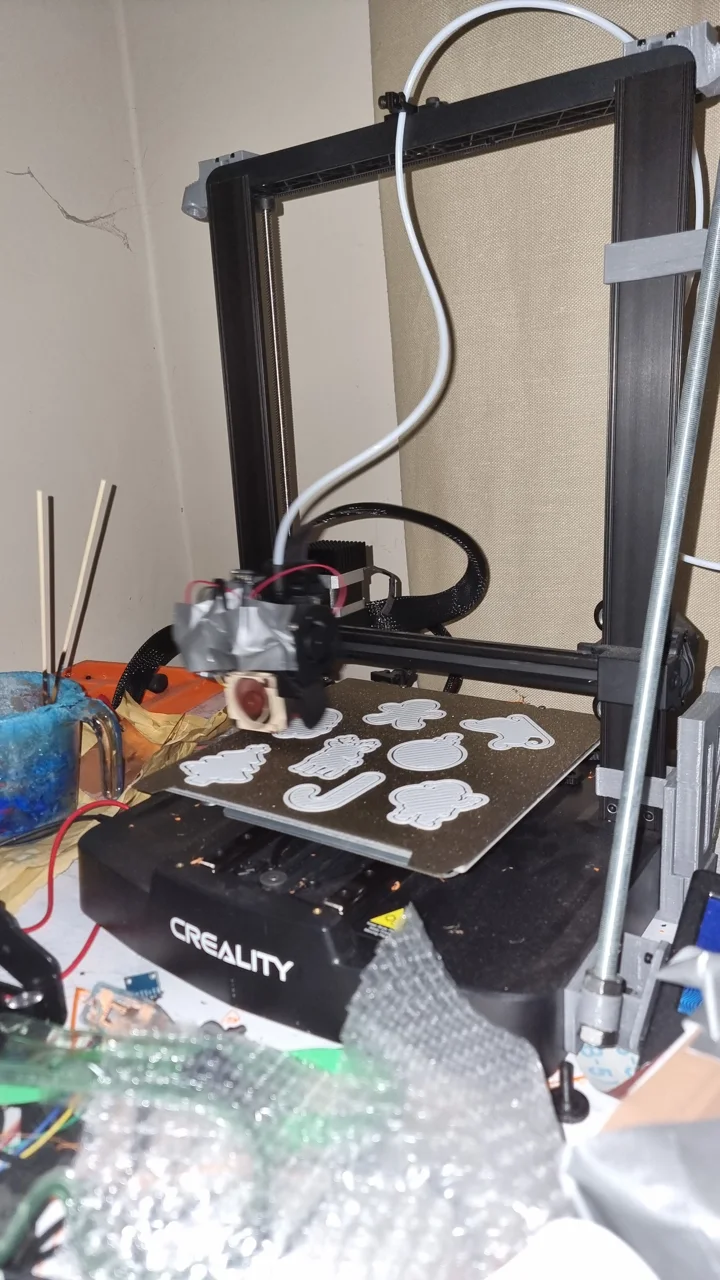
Workshop tools · Hardware & firmware
A printer, rebuilt in stages
Klipper, motion upgrades and custom cooling on a working FDM printer.
View case study
02 / About me
I learn by
making things.
I enjoy the theory behind robotics, but the part I keep coming back to is getting a physical system to work: finding the fault, changing the design, and testing it again.
That has taken me from repairing robotic hardware at Alvis Robotics to designing an anatomical forearm for a medical training prototype. At home, I build and modify printers, electronics and the server that runs my family’s services.
Outside engineering, I’m an Explorer Scout Leader. I founded a new section and run sessions, expeditions and camps for a group of 18 or more young people.
BEng Robotics Engineering
First Class Honours · Queen Mary University of London
IMechE accredited
03 / Experience
Solving problems
on real hardware.
Engineering Design & Research Intern
Hands-on fault diagnosis and repair on explosive ordnance disposal robots.
- Traced a sensor and camera activation fault to incompatible driver boards on a Northrop Grumman unmanned ground vehicle, then replaced the boards to restore operation.
- Disassembled a seized crawler drive and cleared trapped mud from its active-pitch mechanism to return the unit to operation.
- Supported R&D planning with the Managing Director on next-generation EOD robot development.
HSBC
Insight programme, quantitative stream · 2024
AT Medics
Clinical data administration and clinic front of house · 2020–2021